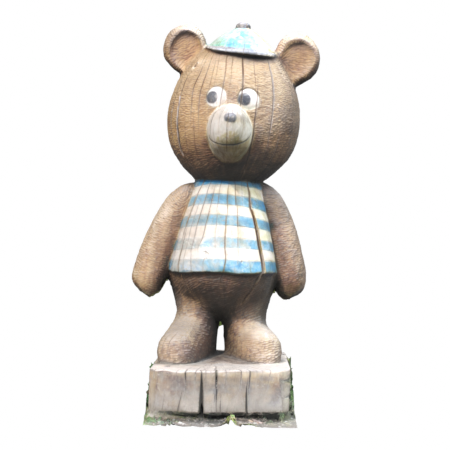
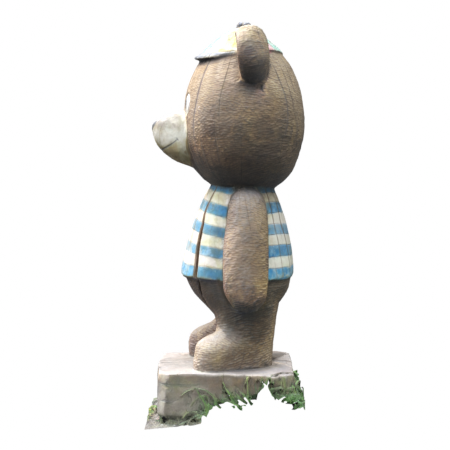
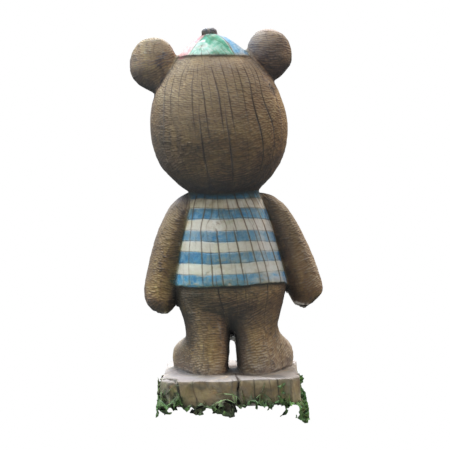
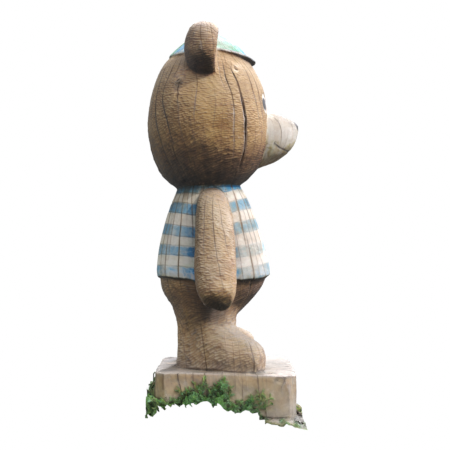
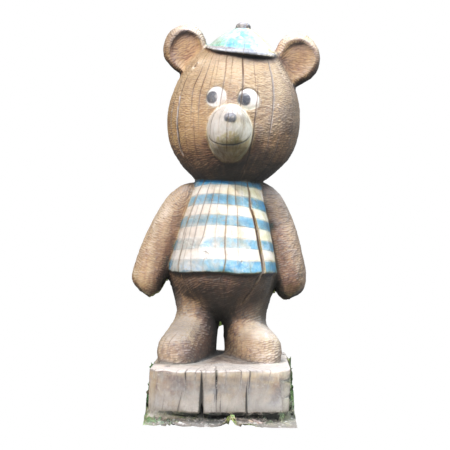
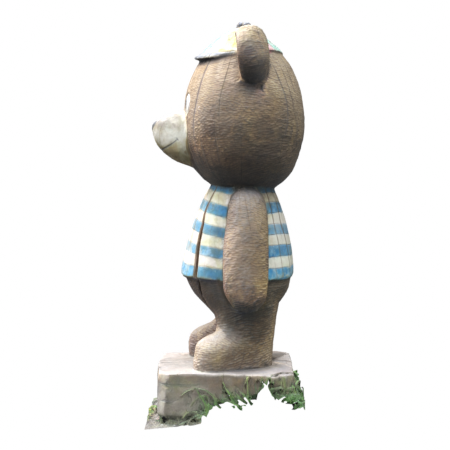
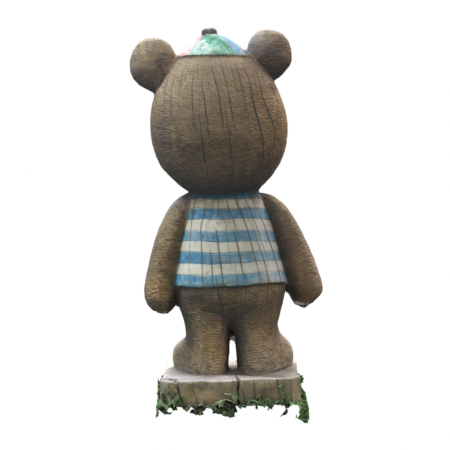
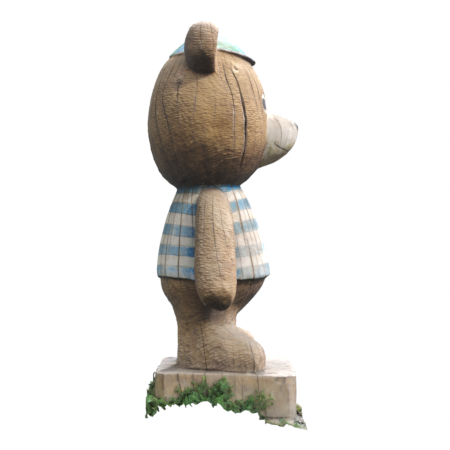
TL;DR: Given a few reference images of an object, OmniShowcase generates a video of that same object along diverse camera paths, even full 360° orbits, keeping its identity and 3D shape consistent by conditioning the video model on a turntable of surface-normal maps reconstructed from the references.
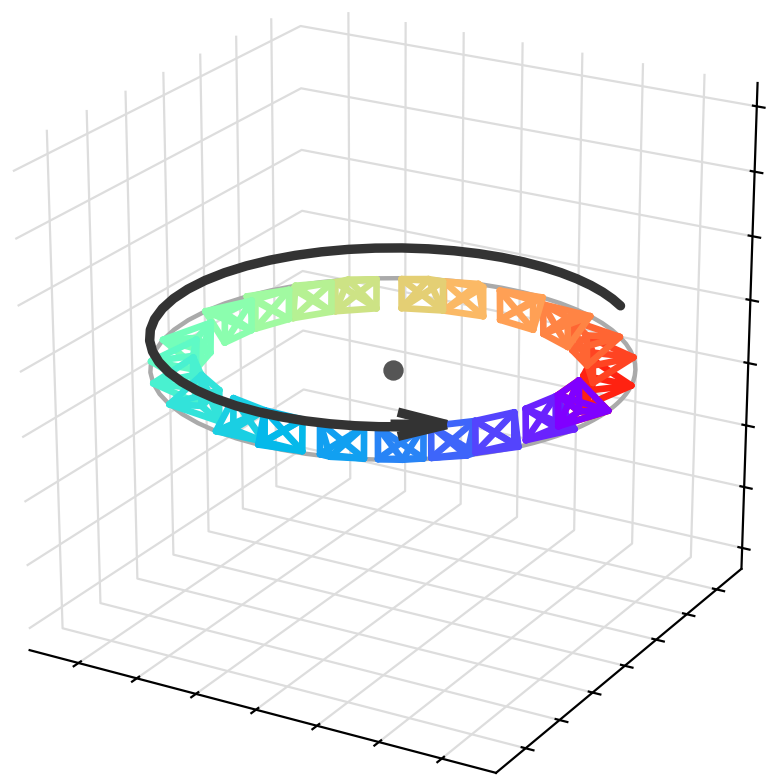
Orbit 360°
→
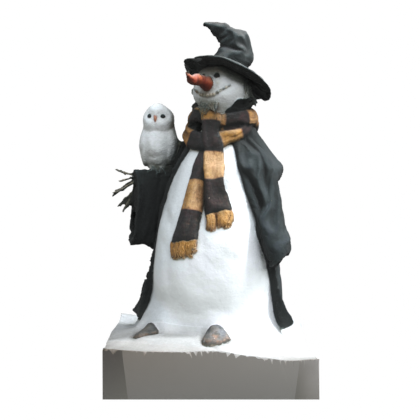
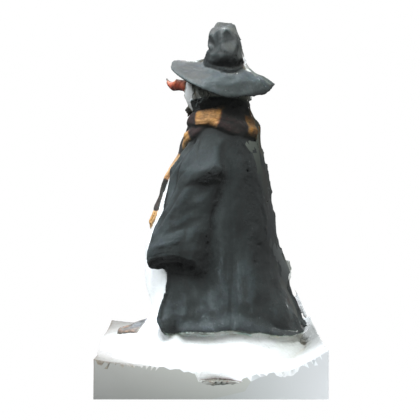
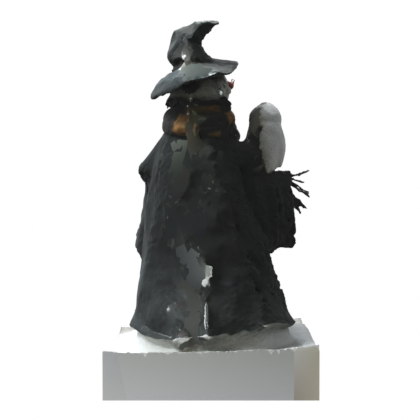
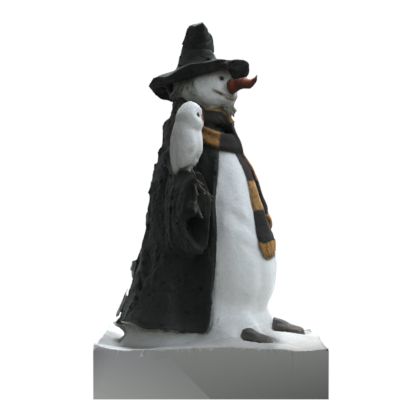
A snowman in a wizard hat and black cloak, hugging a small bird, standing on a floating ice block among glaciers and snow-capped mountains …+ [Orbit 360°]
Helix-Down 360°
→
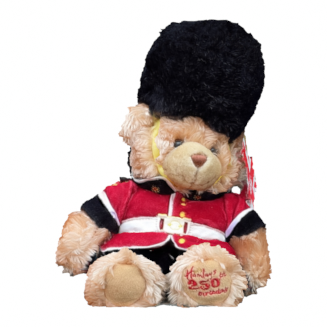
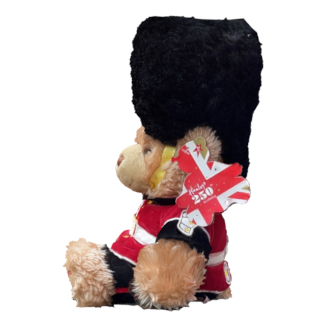
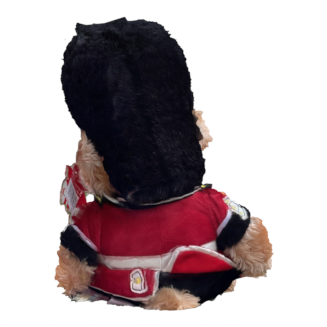
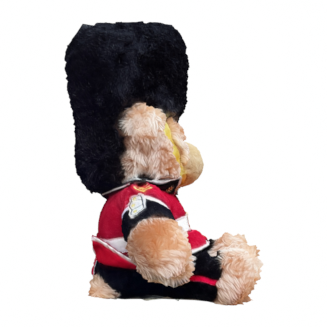
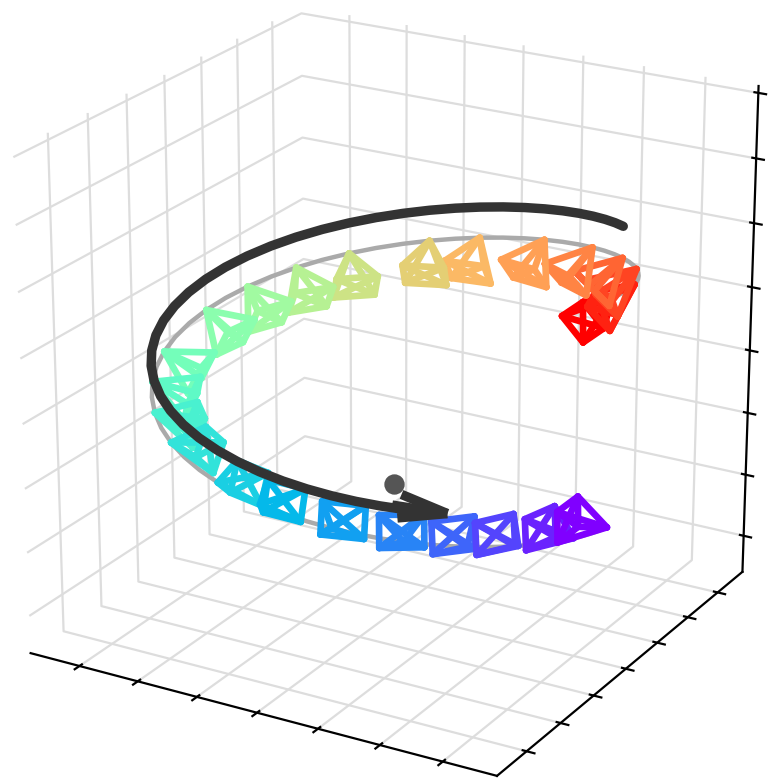
A teddy bear in a red guard uniform on a round rose marble table in a soft pink dressing room, beside a crystal perfume bottle and peony petals …+ [Helix-Down 360°]
Arc-Down
→
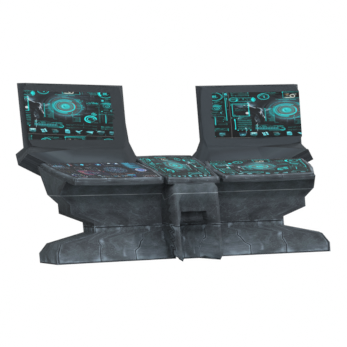
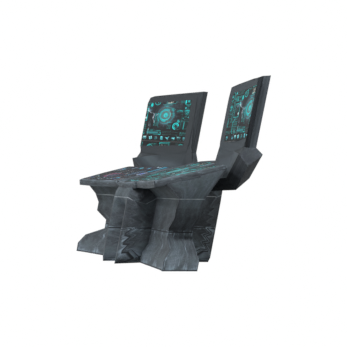
A carved stone sci-fi control console with glowing teal holographic screens on a bright starship bridge, with a panoramic window onto a violet nebula and a ringed planet …+ [Arc-Down]
Helix-Down 360°
→
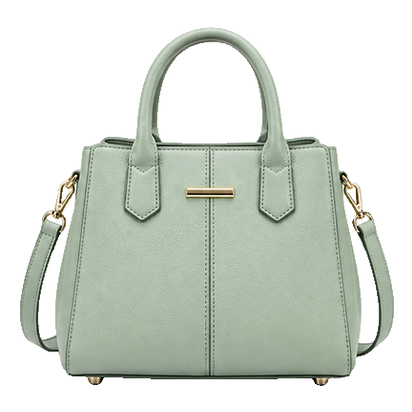
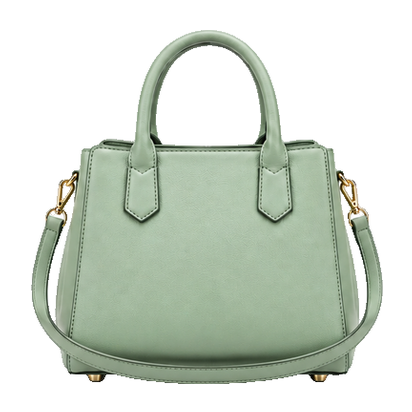
A mint green satchel handbag on a cream velvet stool in an ivory boutique, beside a crystal perfume bottle and a pale blue silk scarf …+ [Helix-Down 360°]
Abstract
Generating videos of a specific subject from a few reference images remains
challenging when the camera reveals surfaces that are not visible in the input.
Early subject-to-video (S2V) methods condition on a single reference image and
must therefore infer the subject's unseen appearance and geometry as the
viewpoint changes. Recent methods extend S2V to multiple reference views,
providing more information about the subject from different viewpoints, but they
do not explicitly specify the 3D structure that connects these observations. In
addition, existing training data do not guarantee that viewpoint changes preserve
the same underlying 3D subject. We present OmniShowcase, built on two
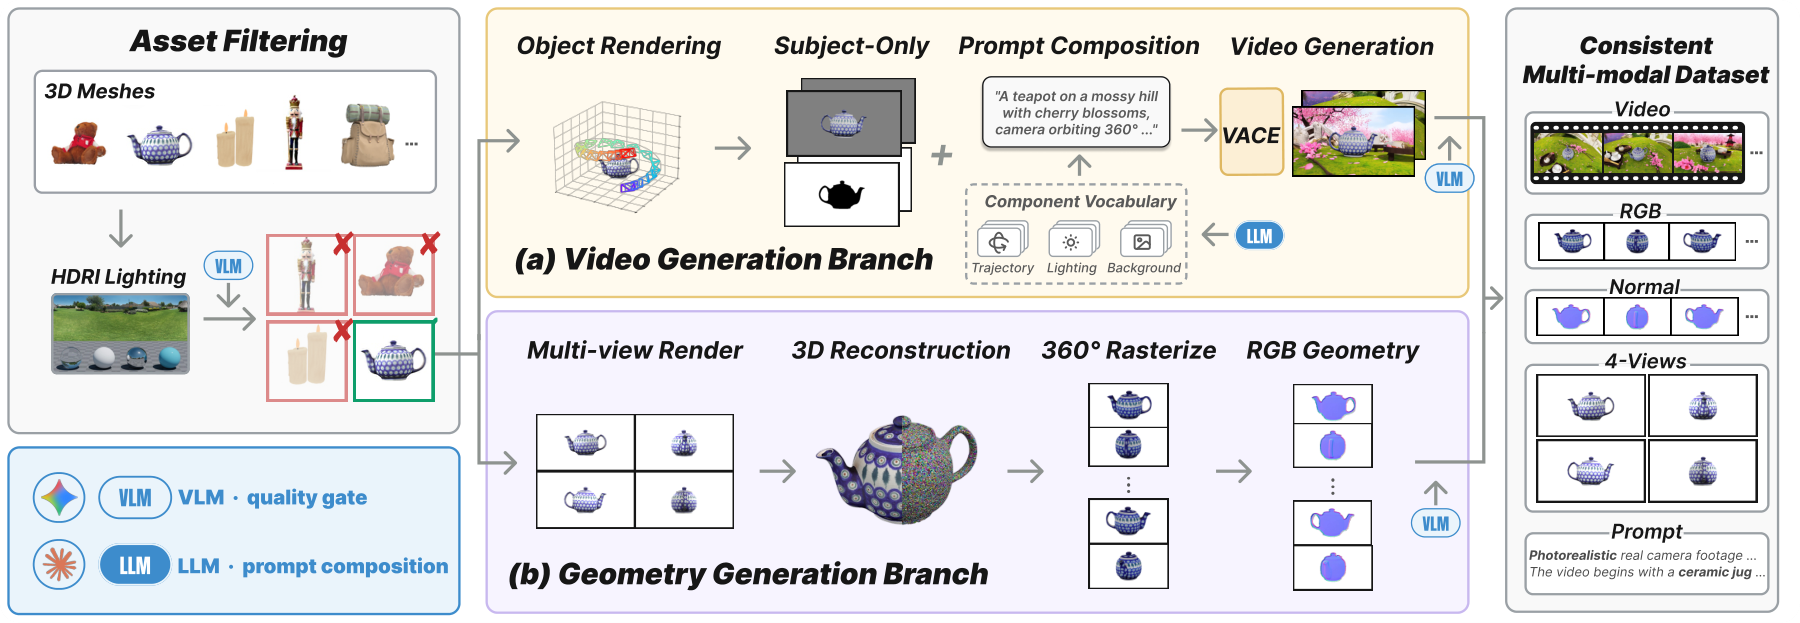
components. First, a fully automated data synthesis pipeline produces training
videos along diverse camera trajectories, with viewpoint variation driven by
underlying subject geometry, even spanning full 360-degree orbits. Second, a
geometry-conditioning method provides the video model with a turntable of
surface-normal maps reconstructed from the reference views, without requiring
temporal alignment with the generated frames. We construct Showcase-4K, a
corpus of 3D-asset-based videos covering twelve camera motions across 88
trajectory configurations with reconstruction-derived surface-normal
conditioning, and ShowcaseBench, a held-out evaluation set that ships the
source meshes and camera parameters used to render each video. Experiments show
state-of-the-art subject identity and 3D consistency while maintaining
competitive video quality and motion.
Method
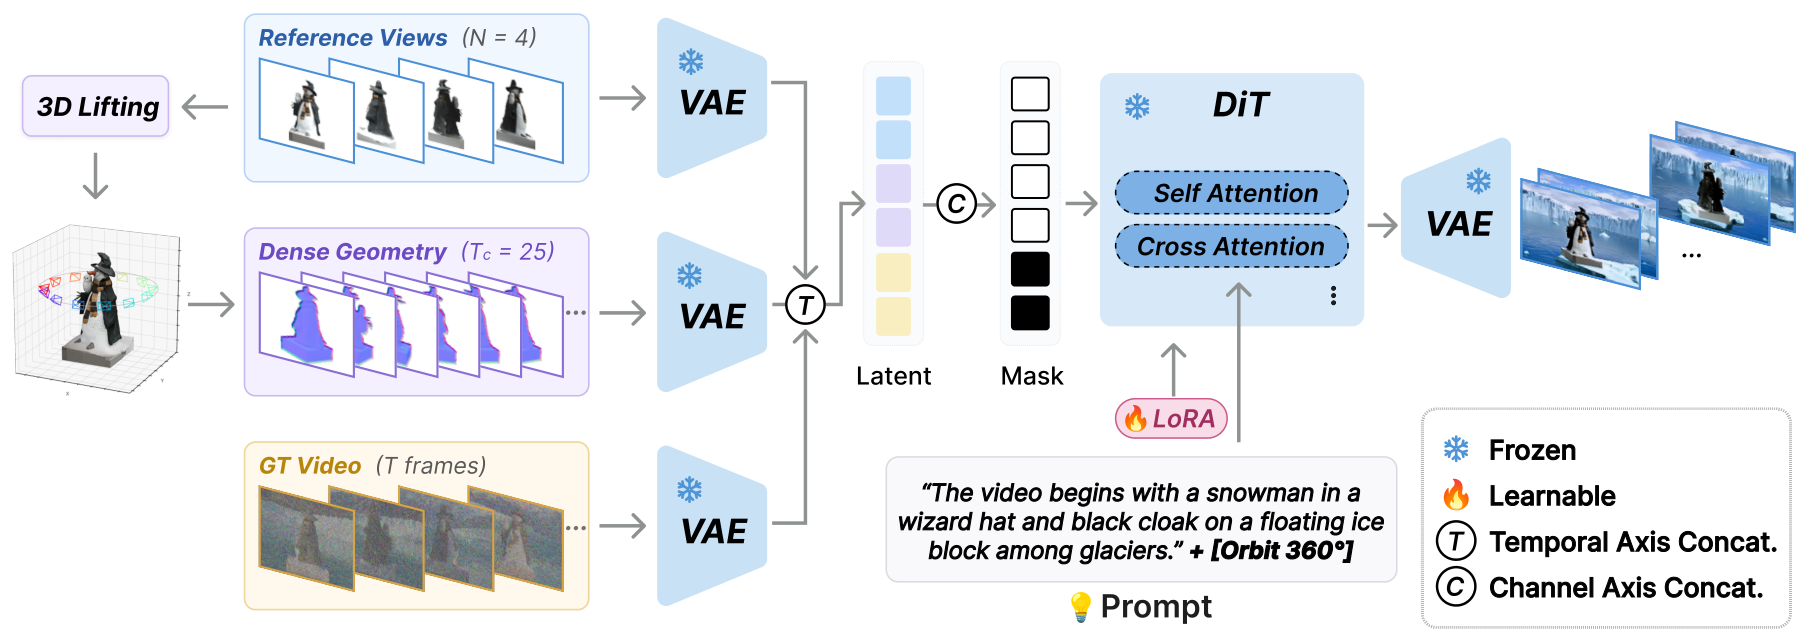
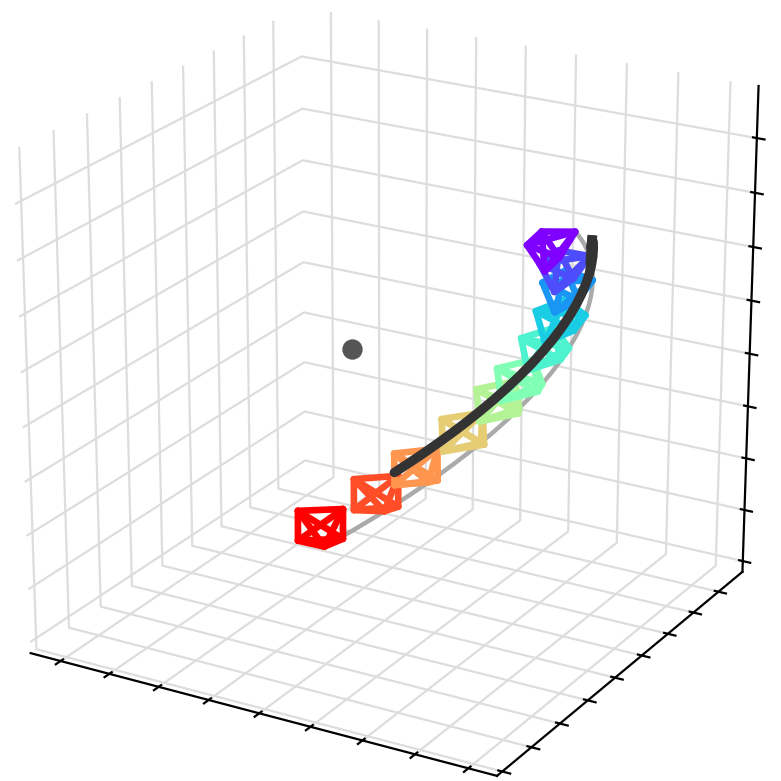
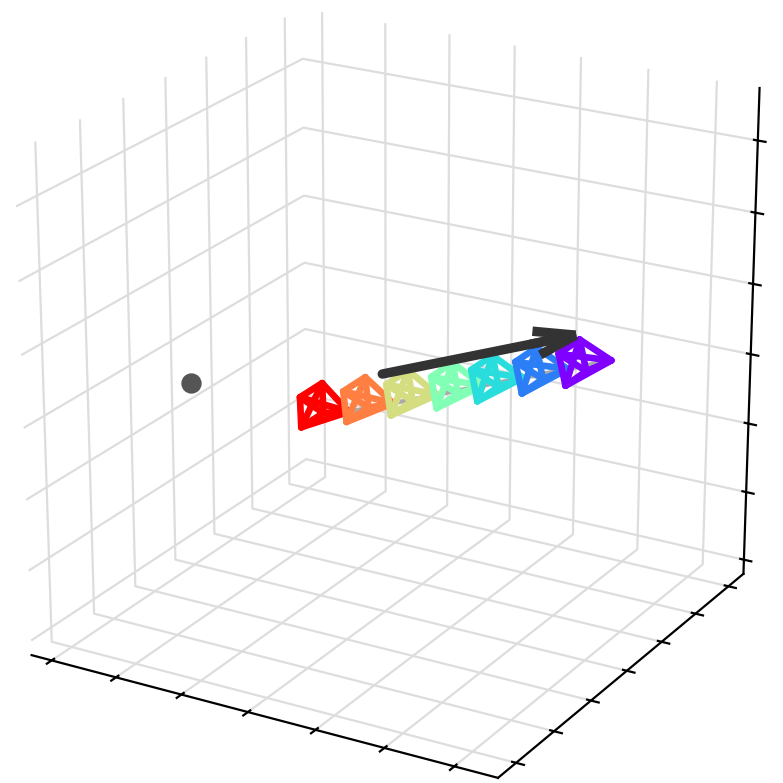
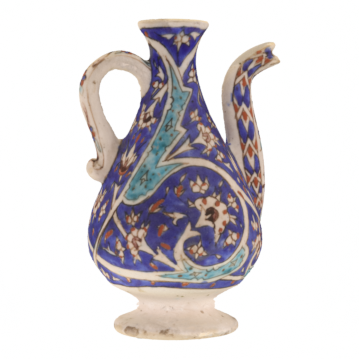
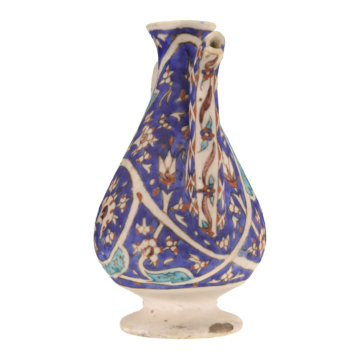
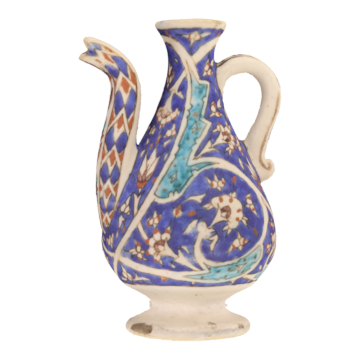
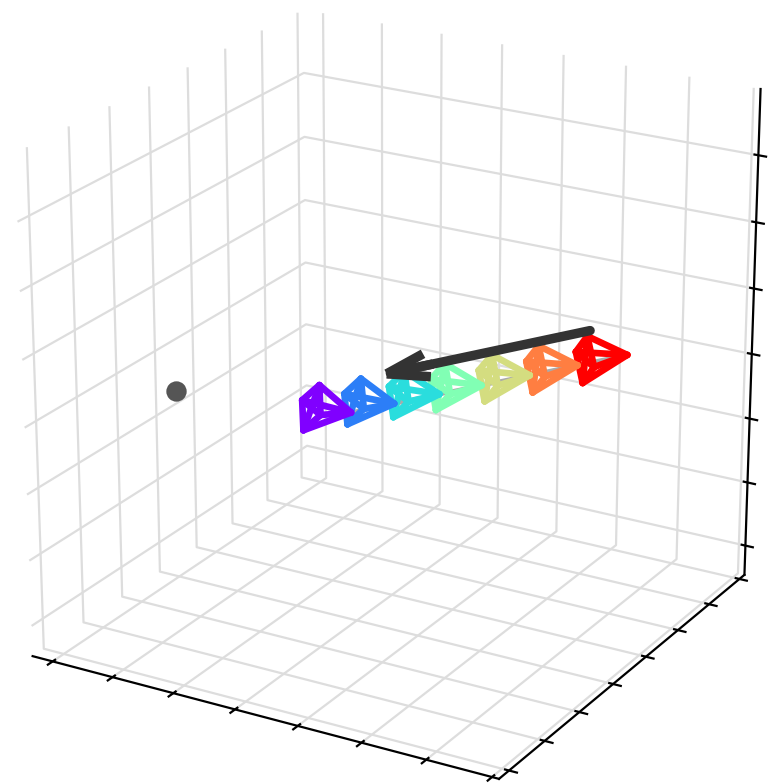
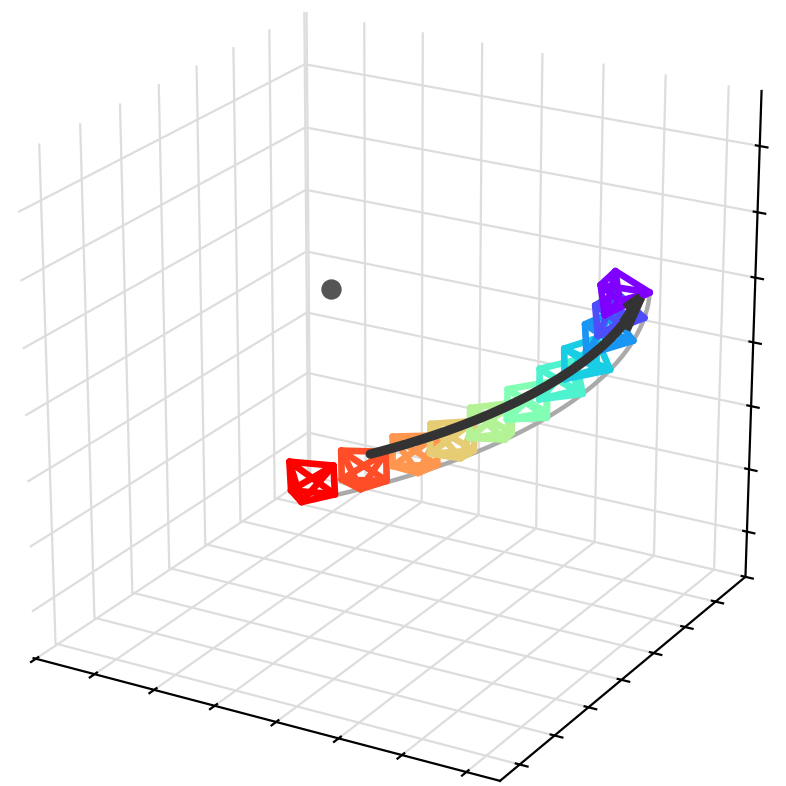
Four reference views are reconstructed in 3D and rendered as a surface-normal
turntable. References and normals are concatenated with the target span and read
in context by a LoRA-tuned image-to-video diffusion transformer.
Data synthesis pipeline. Blender renders the target orbit and four
reference views from one curated 3D asset. The target is composited into a
prompt-driven scene, and the four views are reconstructed and rendered as the
normal turntable used as the condition.
Architecture. The reference images and the normal condition enter the
reference pathway of the diffusion transformer, with no frame-wise alignment
between the normal turntable and the generated video.
Beyond the turntable
The normal condition is a fixed yaw sweep, but the generated camera is not bound
to it. The target follows whichever trajectory the prompt names.
Arc-Up
→
The wooden teddy bear statue on a majolica tile ledge of an Amalfi Coast terrace, among lemon trees, with pastel cliffside houses and a turquoise sea below …+ [Arc-Up]
Dolly-Out
→
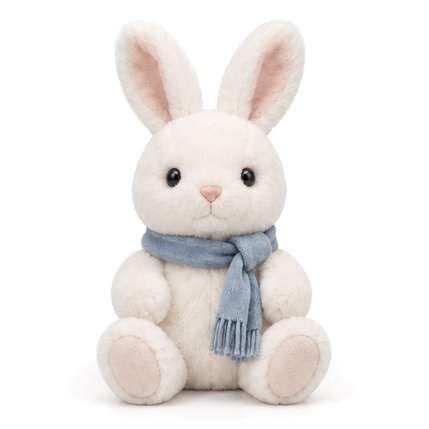
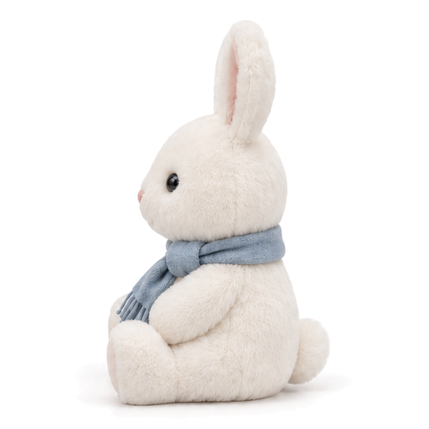
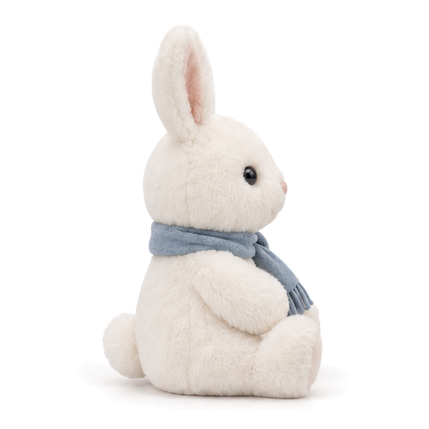
A fluffy white plush bunny with a light blue scarf on a window seat in a bright nursery, next to picture books and a toy hot-air balloon, with cloud wallpaper and a white crib …+ [Dolly-Out]
Comparison with baselines
Same references, same prompt and same trajectory for every method.
ShowcaseBench
Arc-Down
PhantomMAGREFMV-S2V3DreamBoothOurs
The wooden teddy bear statue on the porch of a snow-covered log cabin at dusk, with string lights, firewood, a lantern and snow-laden pines …+ [Arc-Down]
Dolly-In
PhantomMAGREFMV-S2V3DreamBoothOurs
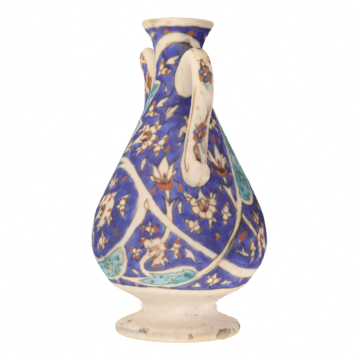
The Iznik ceramic ewer on the edge of a marble fountain in a Moroccan riad courtyard, with zellige tiles, carved arches and palms …+ [Dolly-In]
Arc-In
PhantomMAGREFMV-S2V3DreamBoothOurs
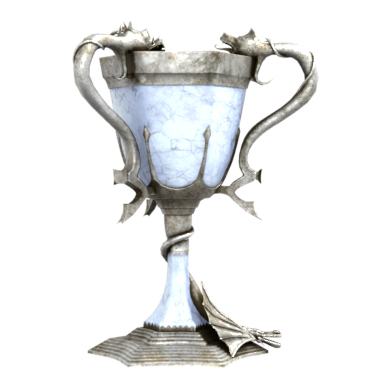
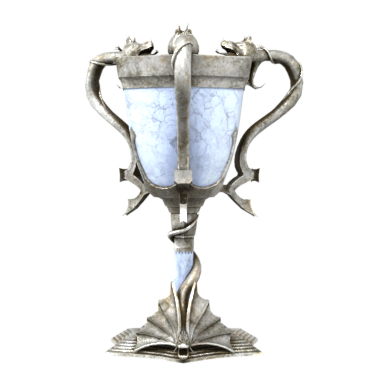
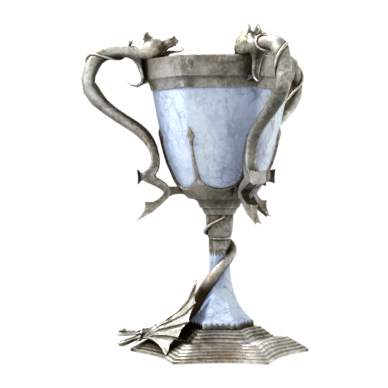
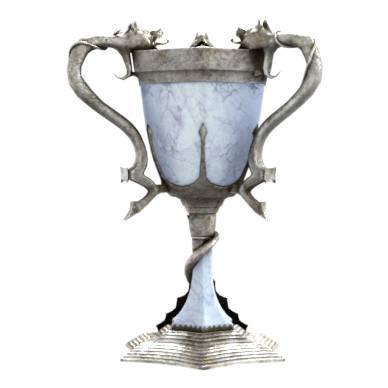
The silver dragon trophy cup on a black obsidian pedestal in a dark stone hall, with a cold blue rim light and drifting embers …+ [Arc-In]
Orbit 360°
PhantomMAGREFMV-S2V3DreamBoothOurs
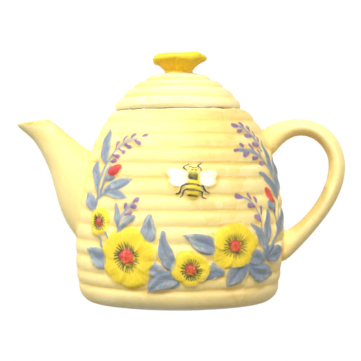
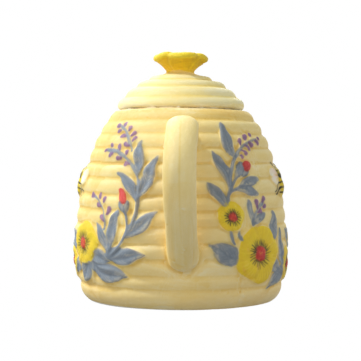
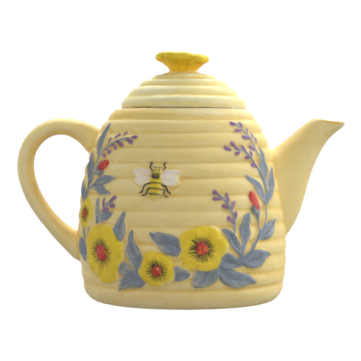
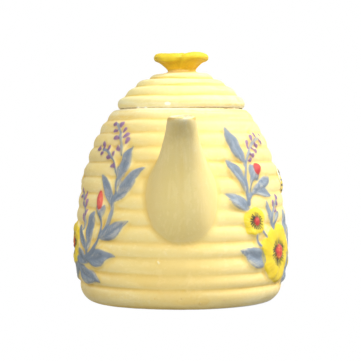
A beehive-shaped teapot painted with sunflowers on a grey linen tablecloth, in front of a limestone wall with climbing vines …+ [Orbit 360°]
NAVI (real-world objects)
Orbit 360°
PhantomMAGREFMV-S2V3DreamBoothOurs
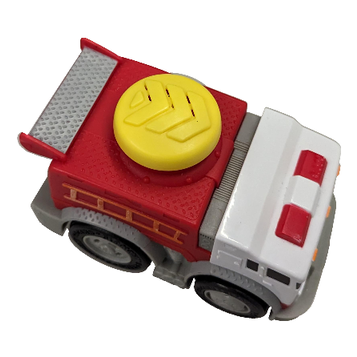
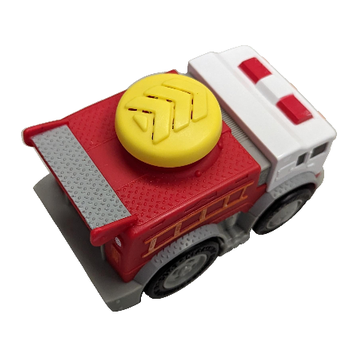
A red and white toy fire truck on a polished wooden desk in a children’s playroom with wall decals and building blocks …+ [Orbit 360°]
Orbit 360°
PhantomMAGREFMV-S2V3DreamBoothOurs
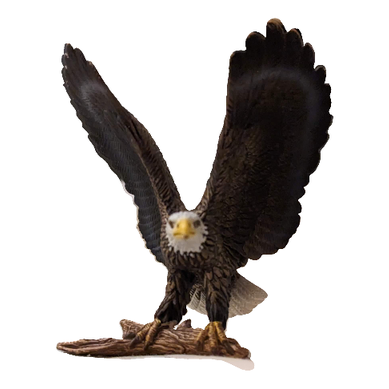
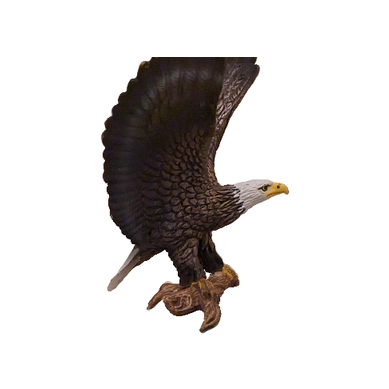
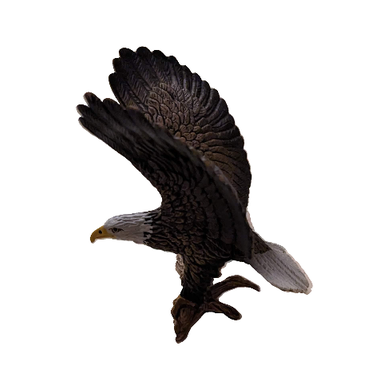
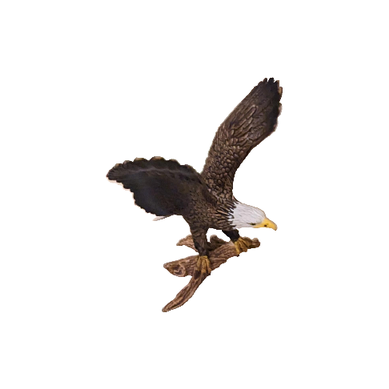
A bald eagle figurine with wings spread on a carved mantel in a mountain lodge …+ [Orbit 360°]
Orbit 360°
PhantomMAGREFMV-S2V3DreamBoothOurs
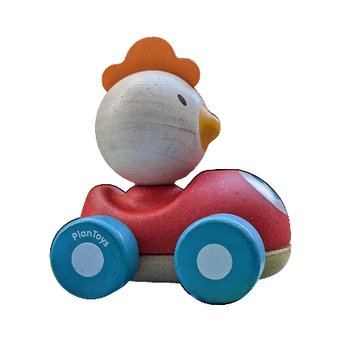
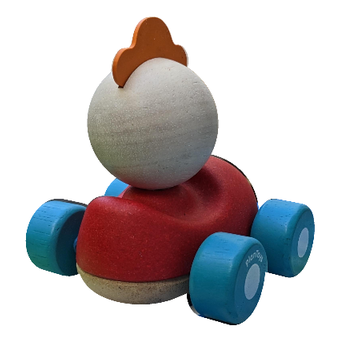
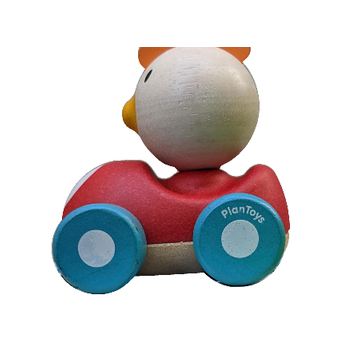
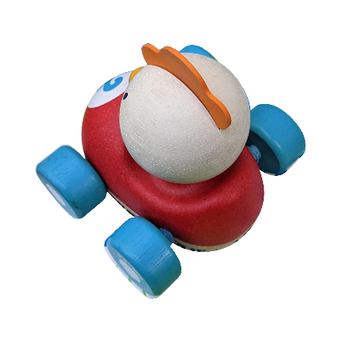
A wooden toy car shaped like a chicken, with a glossy red body and blue wheels, on the marble floor of a grand hotel lobby …+ [Orbit 360°]
Orbit 360°
PhantomMAGREFMV-S2V3DreamBoothOurs
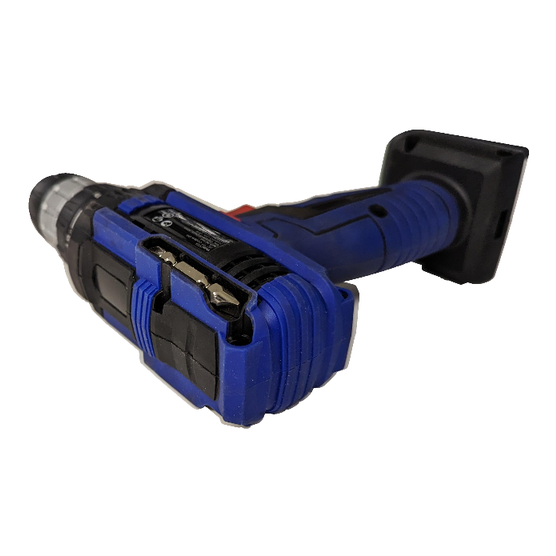
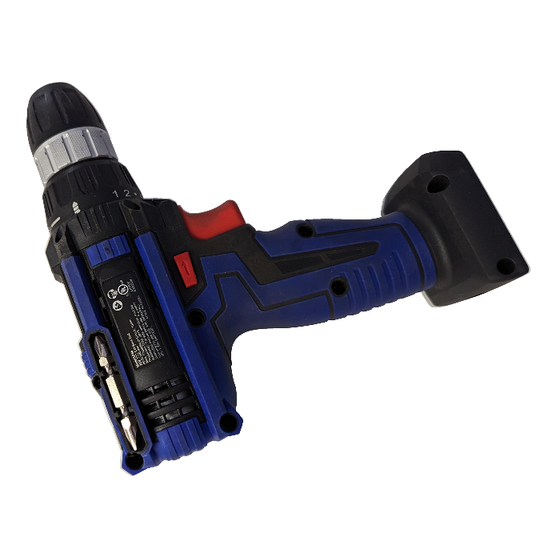
A blue and black cordless drill on a scarred wooden workbench in a home workshop …+ [Orbit 360°]
Quantitative results
Bold is best, underline is second best.
Method
Identity
3D consistency
Text
Video quality
DINO↑
CLIP↑
MEt3R↓
GT-CD↓
RotCov↓
ViCLIP↑
Imaging↑
Aesthetic↑
Dynamic↑
Held-out
Phantom-MV
0.621
0.871
0.444
0.2843
0.906
0.236
72.52
0.595
0.460
MAGREF-MV
0.616
0.876
0.409
0.1789
1.177
0.242
73.88
0.614
0.760
MV-S2V
0.688
0.896
0.351
0.2306
0.787
0.244
73.21
0.590
0.960
3DreamBooth
0.707
0.907
0.325
0.1717
0.765
0.238
70.67
0.598
1.000
OmniShowcase
0.799
0.925
0.190
0.0824
0.665
0.259
74.29
0.574
1.000
NAVI
Phantom-MV
0.690
0.882
0.462
0.2014
1.458
0.255
71.17
0.572
0.029
MAGREF-MV
0.665
0.892
0.457
0.2145
1.284
0.251
69.81
0.574
0.343
MV-S2V
0.770
0.912
0.350
0.1816
1.163
0.250
71.73
0.565
1.000
3DreamBooth
0.741
0.912
0.386
0.2272
1.179
0.244
70.34
0.559
1.000
OmniShowcase
0.828
0.918
0.249
0.0975
1.074
0.260
74.58
0.551
1.000
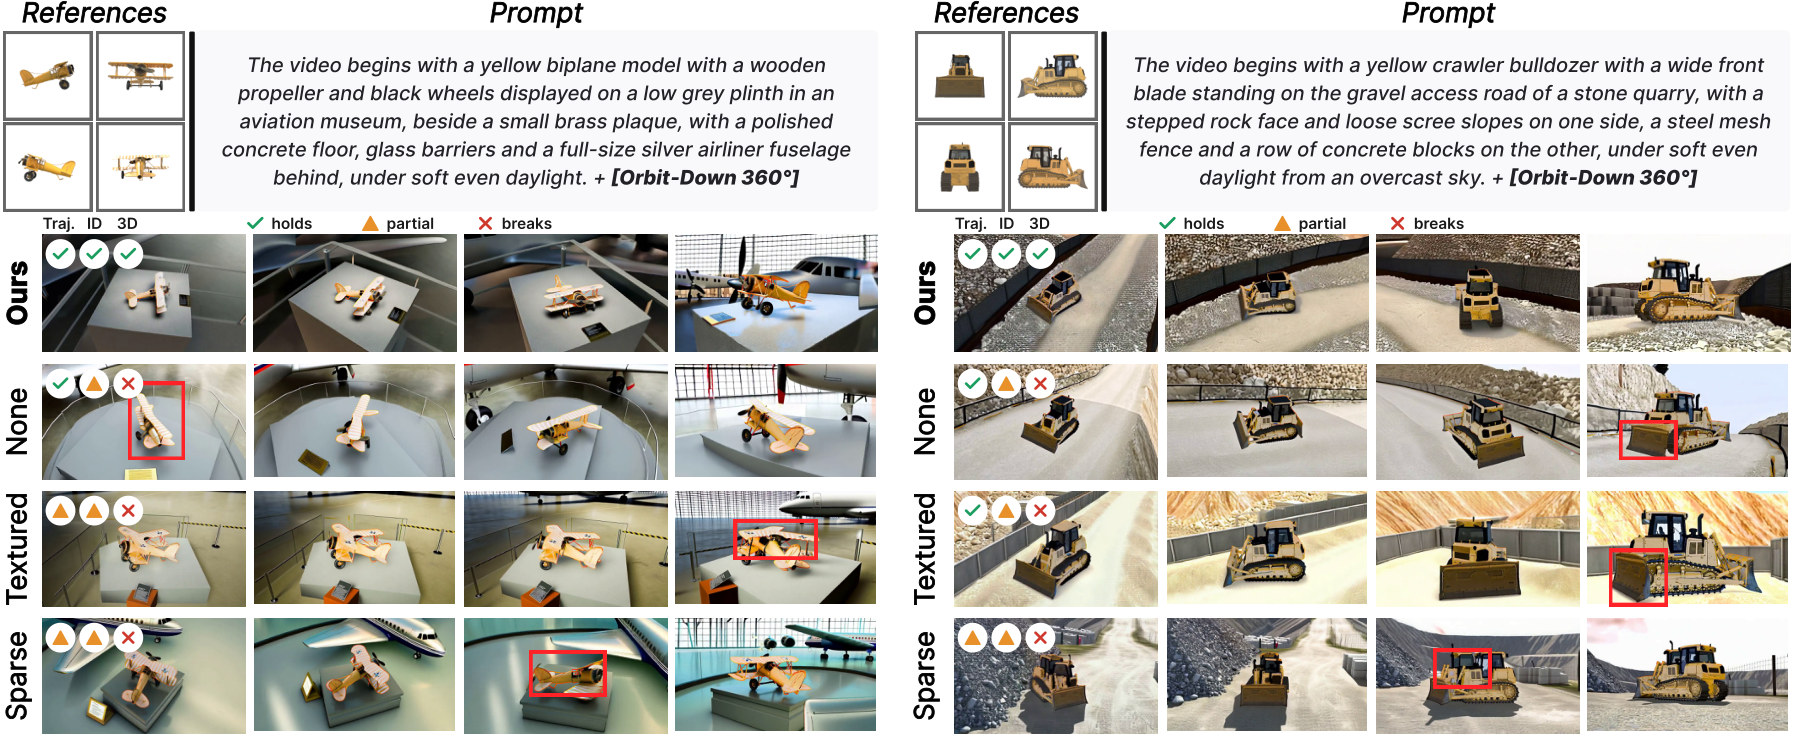
Ablation
Removing the normals, replacing them with a textured render, or thinning the
turntable all degrade identity and 3D consistency.
 Orbit 360°
 Helix-Down 360°
 Arc-Down